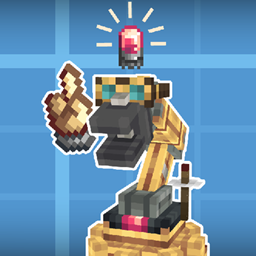
Create: Sequenced Mechanical Arm
Added a handy Sequenced Mechanical Arm that can handle complex tasks through editing.
介绍
Statement: The code for this mod was entirely completed by AI, using DeepSeek Harness, with the model DeepSeek V4.1 Flash.
Create: Sequenced Mechanical Arm · 可编程动力臂
Write a program on an operation table, insert it into the arm, and the arm performs the steps in order — take, deposit, stash, unload, deploy, attack, mine, use, filter, wait, send/receive a redstone-link signal, call a sub-task, return, throw. An addon for Create.
The vanilla mechanical arm only does “A → B”. This one hands you the process: a step table you can edit, save and share — and since every coordinate is relative to the arm that runs it, the same table works on any arm, anywhere, with no edits.
在一张「操作表」上写下一串操作,插进臂里,它就按顺序一件一件地做 —— 取、放、存、卸、组装、 攻击、挖掘、使用、过滤、等待、收发信号、调用子任务、返回、抛错。Create(机械动力)附属模组。
原版动力臂只能”从 A 拿到 B”。这条臂把流程也交给你:一张可编辑、可保存、可分享的步骤表 —— 而所有坐标都是相对执行它的那条臂的,所以同一张表插到任何一条臂上都不需要改。
The items · 物品
-
Sequenced Mechanical Arm — the arm itself. Needs rotation speed, like the vanilla mechanical arm.
-
Operation Table — the program card: holds the whole program (1 main task + sub-tasks) as text.
-
Operation Record Table — a key: sneak-right-click an arm to export its program to a
.smafile. -
Program Import Table — a table: pick a local
.smafile and import it onto a blank operation table. -
可编程动力臂 —— 臂本体,和原版动力臂一样需要转速。
-
操作表 —— 程序卡:一整份程序(1 个主任务 + 若干子任务)以文本形式存在卡上。
-
操作记录表 —— 一把钥匙:潜行右键一条臂,把它的程序导出成
.sma文件。 -
操作导入桌 —— 一张桌子:从本机挑一个
.sma文件,导入到一张空白操作表上。
Quick start · 快速上手
-
Place a sequenced arm, give it rotation speed (adjacent cogwheel, like the vanilla arm).
-
Hold the operation table and sneak-right-click to switch mode (record ⇄ edit).
-
Middle-click a block while holding the table: that position becomes the origin.
-
In record mode, right-click blocks — each click appends a matching operation, with coordinates auto-filled as block you look at − origin.
-
Hold the table and right-click the arm: the program is loaded and starts running.
-
放下「可编程动力臂」,给它转速(和原版动力臂一样,靠旁边的齿轮传动)。
-
手持「操作表」潜行右键切换模式(录入 ⇄ 编辑)。
-
手持操作表中键对着方块:把那一格设成原点。
-
录入模式下对着方块右键 —— 每次追加一条对应操作,坐标自动填成「看向的方块 − 原点」。
-
手持操作表右键动力臂:程序导入这条臂,立刻开始跑。
The operation table · 操作表
One card holds the whole program: 1 main task that loops forever + sub-tasks. Limits: 32 tasks, 1024 entries, notes ≤ 128 characters. The program is stored as text (.sma), so saves are readable, diffable, hand-editable and shareable.
Two modes. Record appends one operation per right-click (an origin must be set first). Edit opens the in-game editor, where every entry can be changed: target coordinates, facing, item count, filter side, unload mode, signal frequency, plus per-entry success exit, failure exit and note. ALT + scroll switches which task you are editing.
Origin and relative coordinates. An entry’s coordinates are always relative: target = arm position + offset. The origin only converts world positions while recording and draws the blue box — it is not part of the program and is not read at runtime.
一张卡装着整份程序:1 个主任务(无限循环)+ 若干子任务。上限 32 个任务、1024 条操作、 单条备注 ≤ 128 字。程序以文本(.sma)形式存盘,所以可读、可 diff、可手改、可发给别人。
两种模式。 录入:右键一次追加一条操作(必须先设原点)。编辑:打开游戏内编辑器,逐条改目标 坐标、朝向、个数、过滤位置、卸货模式、信号频率,以及每条自己的成功后、失败后和备注。 ALT + 滚轮换正在编辑的那条任务。
原点与相对坐标。 条目坐标永远是相对的:目标 = 臂的位置 + 偏移。原点只在录制时把世界坐标换算 成相对坐标、并画那个蓝框 —— 它不属于程序,运行时不读它。
The 14 operations · 14 种操作
| Operation | Coords | Operands | Does |
|---|---|---|---|
take |
yes | count=, countmode= |
take items from the target into the arm |
deposit |
yes | count=, countmode= |
put the held items into the target |
stash |
no | count=, countmode= |
move the held stack into the arm’s own overflow storage |
unload |
yes | mode=as_much / mode=all |
unload the overflow storage into the target |
deploy |
yes | — | apply the held applicator to items on a depot / belt |
attack |
yes | face= |
swing once at that cell (hits an entity) |
mine |
yes | face= |
break the block there (never entities) |
use |
yes | face=, sneak=true |
right-click once; sneak=true = sneak-use |
filter |
container mode only | source=held|container, item= |
compare one item against a filter, then branch |
wait |
no | a time | wait in place |
signal |
no | recv on|off, send_on, send_off, freq=, range=, place= |
redstone-link frequency: receive / send / cut |
call |
no | task name, repeat=, shift= |
run another task, then come back |
break |
no | — | end the current task (return to the caller, or stop the arm) |
throw |
no | one quoted message | fail immediately |
count=is 1–64;countmode=exactrequires exactly N,atmost(default) takes/gives as much as it can.unloadmode=allis atomic: if the target cannot hold everything at once, nothing is unloaded and the arm does not even reach over.signalrange=(0–256) constrains receiving only;place=is the hold time ofsend_on(0t= forever).send_offtakes neither.take/deposit/unload/deployrequire the target to be a Create interaction point;attack/mine/usework on any block.
| 操作 | 坐标 | 参数 | 做什么 |
|---|---|---|---|
take |
要 | count=、countmode= |
从目标取出物品进臂内 |
deposit |
要 | count=、countmode= |
把手上的物品放进目标 |
stash |
不要 | count=、countmode= |
把手上的那一摞收进臂自己的溢出库存 |
unload |
要 | mode=as_much / mode=all |
把溢出库存卸给目标 |
deploy |
要 | —— | 用臂手上的应用物加工置物台 / 传送带上的物品 |
attack |
要 | face= |
对那一格挥一击(打实体) |
mine |
要 | face= |
挖那一格的方块(永远不碰实体) |
use |
要 | face=、sneak=true |
右键一次;sneak=true = 潜行右键 |
filter |
仅容器模式 | source=held|container、item= |
拿一份物品比过滤器,按结果分流 |
wait |
不要 | 时间 | 原地等待 |
signal |
不要 | recv on|off、send_on、send_off、freq=、range=、place= |
红石链接频率:接收 / 发送 / 中断 |
call |
不要 | 任务名、repeat=、shift= |
跑一趟别的任务再回来 |
break |
不要 | —— | 立刻结束当前任务(返回调用方,或收工停机) |
throw |
不要 | 一句带引号的文案 | 立刻失败结束 |
count=取 1–64;countmode=exact要求恰好 N 个,atmost(默认)能取/放多少算多少。unload的mode=all是原子的:目标一次盛不下全部,就一件都不卸,臂也不伸过去。signal的range=(0–256)只约束接收;place=只有send_on有(0t= 一直保持),send_off既没有持续时间也没有距离。take/deposit/unload/deploy要求目标是 Create 交互点;attack/mine/use对任意方块都能试。
Program flow · 走向与分支
-
Every entry has two exits — on success and on failure: skip (continue) or jump to N (entry number inside that task, 1-based;
entries + 1= this round is over). -
timeout=is the retry window: the entry retries in place until it elapses, then the failure exit applies. Notimeout=means retry forever — that is the default. -
callruns another task and comes back (repeat=0= forever,shift=offsets everything that sub-task does). Jumping to a task name instead switches to it — usecallfor a round trip. -
breakends the current task;throwends it as a failure. The main task itself loops forever, so “keep doing this” needs no loop. -
Signals are persistent levels: they stay until something cuts them (
send_off, a card swap, or a stop). -
每条操作都有两个出口 —— 成功后、失败后:跳过(继续下一条)或 跳转 N (本任务内的条目序号,从 1 数;
条数 + 1= 这一轮到此为止)。 -
timeout=是重试窗口:这段时间内原地重试,超时才走失败后。不写就是一直重试 —— 这是默认值。 -
call跑一趟别的任务再回来(repeat=0= 无限,shift=给整个子任务加坐标偏移)。 写任务名的跳转则是换到那个任务去 —— 要”有去有回”请用call。 -
break结束当前任务,throw以失败结束。主任务本身无限循环,所以”一直干这个”不用写循环。 -
信号是持久电平:一直保持,直到有东西清掉它(
send_off、换卡、停机)。
The arm itself · 动力臂本身
-
Right-click with an operation table = load that program (the card is not consumed).
-
Bare hand right-click = take back the item in the arm’s hand.
-
Bare hand + sneak right-click = take one stack out of the overflow storage (LIFO).
-
Inventory: 1 held slot + 10 overflow slots. Full storage never blocks an action; items that cannot be caught simply drop on the ground.
-
Funnels and pipes can only insert into the held slot; overflow slots are extract-only.
-
Create’s engineer’s goggles on an arm show its task, step, state, failure reason, held item, overflow contents and speed.
-
手持操作表右键 = 装载那份程序(卡不会被消耗)。
-
空手右键 = 取走臂手上的那一件。
-
空手潜行右键 = 从溢出库存取走一组(后进的先出)。
-
库存:1 格手持 + 10 格溢出。满仓不阻塞动作,捡不下的掉落物正常掉在地上。
-
漏斗 / 管道只能往手持格输入;溢出格只出不进。
-
戴 Create 工程师护目镜看臂:任务、第几步、状态、失败原因、手持物、溢出内容与转速。
Import & export · 导入导出
Programs are text, and text can live as files: back them up, share them, hand-edit them, keep them in version control. Files are client-side: sequenced_arm/scripts/<name>.sma in the game directory (same treatment as Create’s schematics/ — the server never touches them). Max 60 KB per file.
- Export: the Operation Record Table — sneak-right-click an arm, type a file name, done. Or
/sma code export [name]for the operation table in your hand. - Import: the Program Import Table — a blank operation table in the input slot, pick a script, confirm; the table is only consumed if compiling succeeds. Or
/sma code import <name>. /sma code checkcompiles the table in your hand and lists every error with its line number.- A full bilingual writer’s manual ships with the mod:
sequenced_arm/docs/sma_zh_cn.mdandsma_en_us.mdare written on first launch if missing (files you edited yourself are never overwritten — delete one to get the factory version back).
程序是文本,文本可以落成文件:备份、分享、手改、进版本管理都行。文件在客户端的游戏目录 sequenced_arm/scripts/<名字>.sma(和 Create 的 schematics/ 一个待遇 —— 服务端不碰)。单份上限 60 KB。
- 导出:操作记录表 —— 潜行右键一条臂,输入文件名即可。或
/sma code export [名字]导出主手那张操作表。 - 导入:操作导入桌 —— 输入槽放一张空白操作表,选脚本、确认;编译通过才消耗那张表。 或
/sma code import <名字>。 /sma code check编译主手那张表,把每一处错误带行号列出来。- 模组自带一份中英双语编写手册:首次启动时放到
sequenced_arm/docs/sma_zh_cn.md与sma_en_us.md(你改过的文件不会被覆盖;想要出厂版本就删掉它,下次启动重新生成)。
Requirements · 环境要求
| Minecraft | 1.21.1 |
| NeoForge | 21.1.251 |
| Create | 6.0.10 or newer (required) |
| Java | 21 |
Good to know · 注意
-
Set the origin before recording — without one, recording refuses (there is no base for the relative coordinates).
-
The default failure exit is “retry forever”. If you want “no items → skip”, set the failure exit explicitly.
-
The arm’s reach is Create’s
mechanicalArmRange(default 5 blocks); targets beyond it report an error instead of acting. -
Unloading never dumps items on the ground;
mode=allis atomic,mode=as_muchmay unload partially. -
Programs saved before 0.1.0 were compiled NBT and will not load in current versions — re-record them or import the
.sma. -
录制前先设原点 —— 没有原点时录制会被拒绝(相对坐标没有基准)。
-
「失败后」的默认去向是一直重试。如果想让”没货就跳过”,必须显式设失败后。
-
臂够得着的范围 = Create 的
mechanicalArmRange(默认 5 格),超出会直接报错而不是动手。 -
卸货不会把东西卸在地上;
mode=all是原子的,mode=as_much才可能只卸进去一部分。 -
0.1.0 之前存的是编译后的 NBT,旧存档里的程序读不出来 —— 重录一遍,或把
.sma导回去。
License · 许可
MIT. Built on top of Create (MIT, © simibubi and contributors): the arm’s two-segment IK angles follow Create’s ArmAngleTarget, and the UI pieces (ghost slots, action bar, redstone-link frequencies) reuse the mod itself rather than re-implementing a second set of rules.
MIT 许可。建立在 Create(机械动力)(MIT,© simibubi 及其贡献者)之上:两节臂的 IK 角度解算与 Create 的 ArmAngleTarget 一致,幽灵槽、行为条、 红石链接频率这些机制都直接复用本体,而不是再写一套规则。
常见问题
Create: Sequenced Mechanical Arm 支持哪些 Minecraft 版本?
Create: Sequenced Mechanical Arm 支持 Minecraft Java 版 1.21.1,可用的加载器:NeoForge。下载时注意选择和你游戏版本一致的文件。
Create: Sequenced Mechanical Arm 怎么安装?
先用 PCL2 或 HMCL 启动器安装对应版本的 NeoForge,再把下载的 .jar 文件放进游戏目录的 mods 文件夹,重新启动游戏即可。开启了版本隔离的,mods 文件夹在 versions/版本名 下面。
评论
登录后评论和评分